Artificial intelligence has made remarkable progress in recent years. Large language models can answer questions, generate code, write articles, and have complex conversations. However, most AI systems still exist entirely in the digital world, processing information, producing output, and interacting only through screens and networks.
Physical AI represents the next frontier. Physical AI enables machines to perceive, understand, and interact with the physical world rather than simply manipulating digital data. This is the intelligence layer that enables robots, autonomous vehicles, drones, and smart machines to perform real-world tasks autonomously.
From digital intelligence to physical intelligence
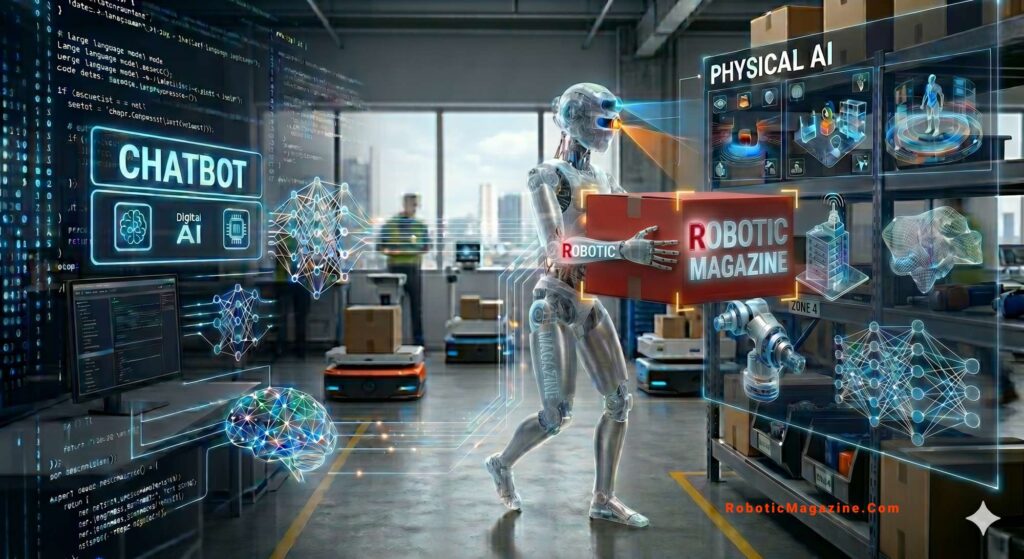
Traditional digital AI systems operate in virtual environments. Chatbots can answer questions, but they can’t take boxes. Image generation models can create realistic images, but they cannot navigate through crowded warehouses.
Furthermore, traditional robotics relies heavily on strict rule-based programming and struggles with unpredictable environments. Physical AI bridges this gap by incorporating modern artificial intelligence into sensors, actuators, and machine control systems. These systems don’t just process data; they also observe their surroundings, make real-time decisions, and safely perform physical actions.
Digital AI Understand and process information.
physics AI Perceive, reason, and act in the physical world.
Core components of physical AI
Physical AI systems rely on multiple interconnected layered technologies to function seamlessly.
sensing
The robot must first capture data from the environment. To achieve this, we utilize a series of advanced sensors.
- Space and navigation: Camera, LiDAR, Radar
- Kinematics and forces: IMU (Inertial Measurement Unit), Force Sensor, Torque Sensor
This multimodal data allows the system to detect obstacles, recognize people, estimate distance, and monitor changing environmental conditions.
world modeling
Raw sensor data alone is not enough. Physical AI systems need to build a dynamic internal representation of their environment.
This internal representation is often world modelhelps robots answer basic questions.
- where am i?
- What objects are around me?
- What’s going on?
- What happens next?
World models provide the predictive foundation needed for intelligent decision-making.
Reasoning and planning
Once the system understands its surroundings, it evaluates possible actions and selects the safest and most efficient path to the goal.
For example, a warehouse robot may need to maneuver around a moving forklift as it transports a package to a specific location.
Increasingly incorporated into modern physics AI End-to-end learning This approach allows neural networks to directly link perception to action. However, many production systems still combine learned models with traditional planning and control algorithms to maximize reliability and safety.
action and control
Once a decision is made, the control system translates the high-level goals into precise mechanical movements. Adjust motors and actuators to ensure actions are performed accurately.
Humanoid robots require advanced whole-body control to maintain balance, coordinate dozens of joints simultaneously, and continuously adjust forces in real time.
learn
Physical AI systems refine their behavior through experience. Machine learning and reinforcement learning techniques allow robots to adapt to changing conditions, improve performance, and become more efficient over time.
As robots repeatedly perform tasks, they gradually discover ways to complete them faster, safer, or more energy-efficiently.
Why physical AI is harder than chatbots
Operating in the physical world presents challenges that digital AI will never encounter.
If a chatbot generates an incorrect answer, the result is usually incorrect information. If a robot makes a mistake, it can damage equipment, interrupt work, or endanger people nearby.
Physics AI must ensure that:
- Uncertainty and special cases
- Real-time decision making
- safety requirements
- Hardware limitations
- dynamic environment
Robots must deal with slippery surfaces, changing lighting conditions, unexpected obstacles, sensor noise, and human movement.
As a result, physical AI requires tight integration of software intelligence, sensing systems, control algorithms, and mechanical engineering reliability.
The role of simulation and the challenge from simulation to reality
Training robots directly in the physical world is often time-consuming, expensive, and can damage the hardware.
To overcome these limitations, developers are increasingly relying on advanced simulation platforms that allow robots to practice millions of interactions before touching the real world.
One of the best-known examples is NVIDIA’s physical AI ecosystem. NVIDIA Omniverse and Isaac Sim. These platforms allow developers to build digital twins, generate synthetic training data, and simulate robots in highly realistic virtual environments before deployment.
Developers can explore these platforms by:
However, simulation is only part of the challenge.
Engineers must also overcome Gap between simulation and reality—The difference between virtual environments and the chaotic reality of the physical world. A robot that performs perfectly in simulation may encounter unexpected lighting conditions, sensor inaccuracies, hardware wear, or environmental changes after deployment.
To reduce this gap, researchers use techniques such as domain randomization, synthetic data generation, and large-scale reinforcement learning.
Physical AI and humanoid robots
Humanoid robots are one of the most ambitious applications of physical AI.
Unlike industrial robotic arms that operate in highly structured environments, humanoid robots are expected to function in spaces designed for humans. They must walk, climb stairs, manipulate tools, avoid obstacles, and interact safely with people.
To perform these tasks, combine the following:
- advanced perceptual system
- world model
- motion planning
- whole body control
- machine learning
For many robotics companies, physical AI is not just a feature, but the underlying architecture needed to enable general-purpose robot functionality.
The rise of the Vision, Language, Action (VLA) model
One of the most promising developments in physical AI is Vision, Language, Action (VLA) Model.
These architectures integrate three important domains:
- vision to understand the environment
- language to interpret human instructions
- action For control of physical systems
VLA-enabled robots can understand commands such as:
“Pick up the red box and put it on the top shelf.”
The model interprets the instructions, identifies the correct object, plans the necessary movements, and performs the task.
This represents a major shift from rigid programming to adaptable machines that can perform a variety of tasks with minimal task-specific coding.
The future of physical AI
Many researchers and industry leaders believe that physical AI has the potential to be one of the defining technologies of the next decade.
As AI models, high-fidelity simulation environments, computing hardware, and sensor technology continue to advance, physical AI systems are expected to become even more capable and autonomous. Recent efforts such as NVIDIA’s robotics-focused Isaac and GR00T platforms reflect the industry’s growing efforts to develop more general-purpose robot intelligence.
Potential applications span numerous industries.
- manufacturing industry
- Warehousing
- construction
- agriculture
- health care
- logistics
- home support
- self-driving traffic
- Space and deep sea exploration
The transition from digital intelligence to physical intelligence has already begun.
conclusion
Artificial intelligence is being liberated from screens and data centers.
Physical AI extends digital intelligence into tangible reality, providing the perception, reasoning, planning, and control capabilities needed for next-generation autonomous systems. By combining sensors, world models, simulations, machine learning, and robotics, Physical AI enables machines to not only understand information but also interact meaningfully with the world around them.
While chatbots have demonstrated what AI can do with information, physical AI is beginning to demonstrate what AI can do with reality itself.
Posted by: A. Tutor
Terms: Unauthorized reproduction is prohibited. We maintain a date record to record the original publication. The content may contain inaccuracies. All trademarks mentioned are the property of their respective owners. We are not affiliated with them and do not imply any warranty. Please see the terms and conditions page.